sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

With the control system developed by the Austria automatic company SIGMATEK GmbH & Co KG, SWITEK high speed side entry IML robot is providing a more efficient and outstanding performance for your quality bulk production of the IML Yogurt Cups.
Programs run from the top down; they can jump to the corresponding label part when they need to jump, or they run from the top down.
Example 1: Uniaxial running cyclically:
Motion logic: SX1 run to 0; delays 1s, SX1 run to 100mm, delay 1s, SX1 run to 0 …… Repeatedly like this manner
Key icon: Label Mark, SX1 run, Delay, Label Mark Jump
Program can be compiled as the below picture:

Example2: Standby/Stacking/Get Label
For the reason that the corresponding parameters about Standby/Stacking/Get Label need to be set in single page, it just need to drag the relative icons to the teaching compiling. As shown in the below picture:

Example 3: Output cyclically/Cut off the first output:
Motion logic: output 1 on; output 1 off; output 1 on …… repeatedly like this manner Key icon: Label Mark, Set Output, Label Mark Jump
Program can be compiled as the below picture:

Example 4: Wait Input 1 on/off, then run the next step:
Motion logic: Wait Input 1 on, SX1 run to 200mm; Wait Input 2 off, SX1 run to 0 mm
Key icon: Wait Input, SX run
Program can be compiled as the below picture:

Example 5: Transfer subprogram, Wait subprogram, Run the next step:
Motion logic: Transfer subprogram 2, wait subprogram 2, then SX1 run to 1000mm
Key icon: Execute Program, SX1 run, Wait Program
Program can be compiled as the below picture:

Example 6: The former 3 groups of production, lay by the Stacking 1; the rest production, lay by the Stacking 2.
Motion logic: Estimate the amount of variable 1 whether or not more than 3; if more than 3, label mark jump to the program of Stacking 2; if less than 3, run the next step straight (Stacking 1 program); after finishing stacking, variable 1 increases 1 (as 0 former, increasing to 1; as 1 previously, increasing to 2); program will jump to Label Mark after variable increasing, or it will run the next step continue.
Key icon: Label Mark, VariableJump, Stacking, Variable Increase (enumerative efect), Label Mark Jump
Program can be compiled as the below picture:

Example 7: Stacking lays 10 productions firstly, and it will lay another 10 productions more when the conveyor goes ahead 10s. Then goes on as the above method …
Motion logic: Estimate the amount of variable 1 whether or not more than 10; if more than 3, label mark jump to the program of conveyor; if less than 10, return to restart the new steps;
Notice: If program needs stacking renewedly at the begin, variables need to be cleared into 0 before the cyclical motion. If not, these variables will base the former scale on counting when the program restart. This situation can result in the amount of production will not reach 10 at the first time of conveyor belt run.
Key icon: Label Mark, Stacking, Variable Increase (Count effect), Label Jump Mark
Program can be compiled as the below picture:


SW818
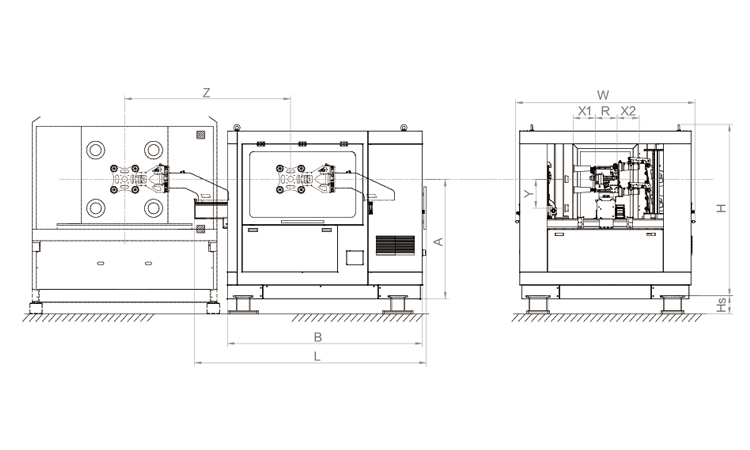
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 190 | 190 | 0 | 0 | 400 | 0 | 0 | 2100 | 2730 | 2410 | 1720 | 5kg |
|---|
EOAT Assembly Demonstration -- One Cavity Instrument Panel Picking EOAT
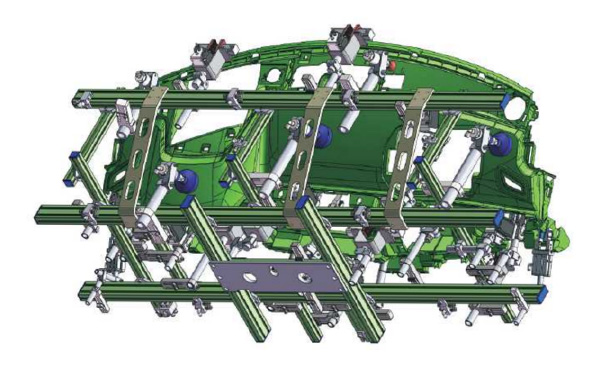
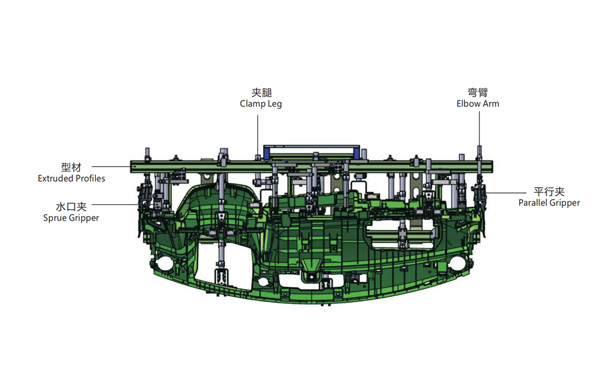
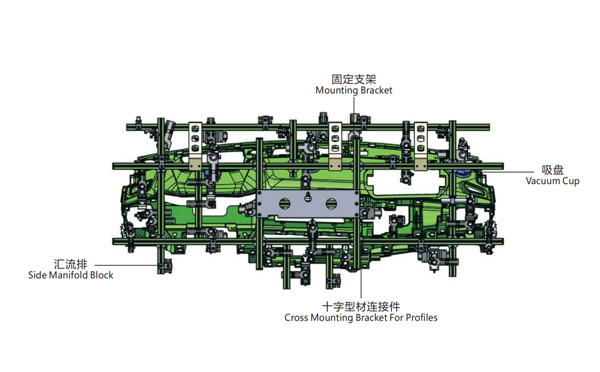
Product Descriptions
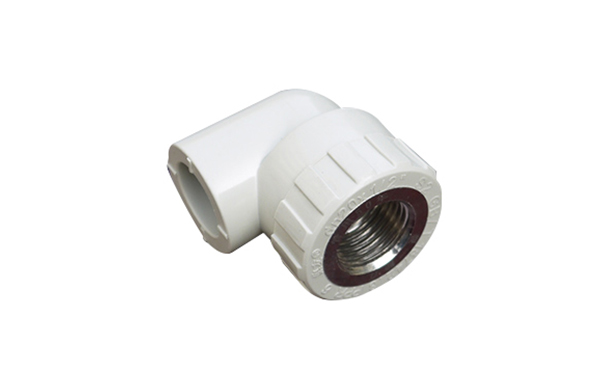
Why is 8 Cavities Mold Design the Best Solution for Elbow with Nuts?
For PVC/PPR pipe fittings with nuts with a diameter of around φ25mm most of the producer will choose an injection molding machine of around 250T and a mold cavities of 8 Cavities, will a more cavities mold design with a larger injection molding machine a better choice for pipe fittings producers?
According to the experience of working with LESSO group in the automiztion of their PVC/PPR pipe fittings injection production system, we finally decide to have an 8 cavities mold deisgn with 250T injection molding machine because:
Anyway, to upgrade your PVC/PPR pipe fittings injection molding system you must keep in mind that it's only valuable to have an automation system for bulk production products, which means that one injection molding machine with only one mold to be equipped with one automation system for the pipe fittings' Nut insertion, runner cutting and parts picking.
For any other question about a PVC/PPR pipe fittings auto-production system please contact Adams from SWITEK for a turn-key solutions of pipe fittings production.