sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

Keywords:PETRI DISH PACKING SYSTEM, PETRI DISH INJECTION MOLDING SOLUTIONS
The position setting pages are for the operator of the SWITEK petri dish packing system from where should the robotic arms to pick the petri dish and by where should the petri dishes to be placed or stacked or packed. Here in this chapter we'll introduce the setting of the position of the axis of the SWITEK side entry petri dish packing system.
Position Setting 1
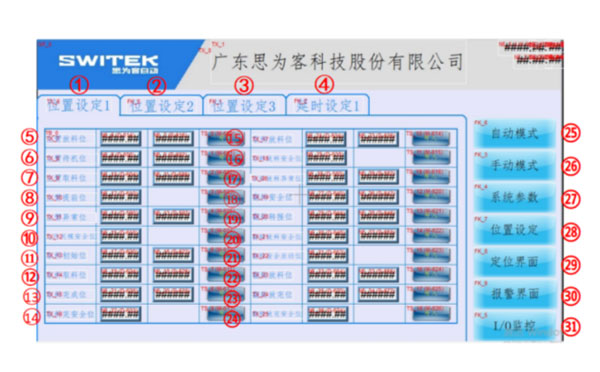
| No. | Description |
|---|---|
| 1 | Position Setting 1 (Pos Set 1) 400 |
| 2 | Position Setting 2 (Pos Set 2) 401 |
| 3 | Position Setting 3 (Pos Set 3) 402 |
| 4 | Delay Setting 1 (Delay Set 1) |
| 5 | Main Arm Parts Relese Position (Main Arm Rel) 425 |
| 6 | Main Arm Standby Position (Main Arm Sby) 426 |
| 7 | Main Arm Petri Dish Picking Position (Main Arm Coll) 427 |
| 8 | The Position where the Main Arm Allowed to Start a Pre-active (Main Arm Adv) 428 |
| 9 | The Main Arm Exception Position (Main Arm Exc) 429 |
| 10 | Mold Close Enable Position (Allow Mold Close Safe) 430 |
| 11 | Petri Dish Picking Initial Position (Mat Coll Init) 431 |
| 12 | Petri Dish Picking Position (Mat Coll) 432 |
| 13 | Petri Dish Picking Finish Position (Mat Coll Cmp) 433 |
| 14 | Petri Dish Picking Finish Safe Position (Mat Coll Safe) 434 |
| 15 | Petri Dish Picking and Placing Position (Mat Rel) 435 |
| 16 | |
| 17 | Petri Dish Abnormal Picking/Placing Position (Anomaly Location) 582 |
| 18 | Flipping Safe Position (Flip Safe) 437 |
| 19 | Flipping Transfer Position (Flip Trans) 438 |
| 20 | Flipping & Petri Dish Placing Safe Position (Flip Rel Safe) 439 |
| 21 | Flipping Safe Starting Position (Flip Safe Start) 440 |
| 22 | Petri Dish Flipping Place Position (Flip Rel) 441 |
| 23 | Petri Dish Flipping Place Finish Position (Flip Cmpl) 442 |
| 24 | Petri Dish Flipping Place Finish Safe Position (Flip Cmpl Safe) 443 |
| 25 | Auto Mode (Auto) |
| 26 | Manual Mode (Manual) |
| 27 | System Parameters (Sys Params) |
| 28 | Position Settings (Pos Set) |
| 29 | Position Interface (Pos Interface) |
| 30 | Alarm Interface |
| 31 | I/O Monitor (I/O Mon) |
Position Setting 2
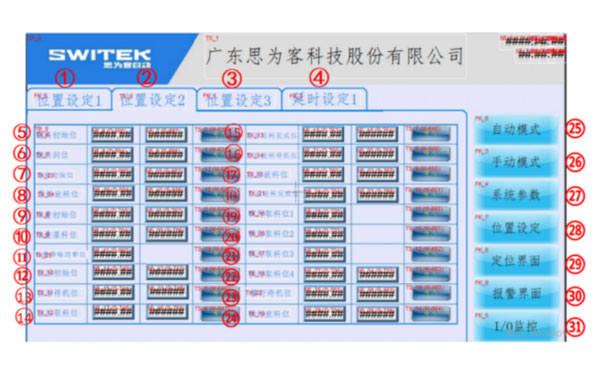
| No. | Description |
|---|---|
| 1 | Position Setting (Pos Set 1) 400 |
| 2 | Position Setting (Pos Set 2) 401 |
| 3 | Position Setting (Pos Set 3) 402 |
| 4 | Delay Setting (Delay Set 1) 403 |
| 5 | Petri Dish Flipping Initial Position (Flip Init) 405 |
| 6 | Petri Dish Flipping In Place (Flip) 406 |
| 7 | Petri Dish Dropping Initial Position (Init Blanking) 583 |
| 8 | Petri Dish Dropping Position (Blank Discharging) 584 |
| 9 | Petri Dish Stacking Initial Position (Stack Init) 407 |
| 10 | Stacked Petri Dish Dropping Position (Stack Drop) 408 |
| 11 | Petri Dish Stacking Conveyor Stop Position (Stop Conveyor) 585 |
| 12 | Up/Don Initial Position (Up-Dwn Init) 409 |
| 13 | Up/Down Standby Position (Up-Dwn Sby) 410 |
| 14 | Up-Down Petri Dish Collecting Position 411 |
| 15 | Up-Down Petri Dish Collecting Complete Position (Up-Dwn Coll Cmpl) 412 |
| 16 | Up-Down Petri Dish Release Standby Position (Up-Dwn Rel Sby) 413 |
| 17 | Up-Down Petri Dish Release Position (Up-Down Rel) 414 |
| 18 | Up-Down Petri Dish Release Finished Position (Up-Down Rel Cmpl) 415 |
| 19 | Horizontal Petri Dish Collecting Position (Horiz Coll1) 416 |
| 20 | Horizontal Petri Dish Collecting Position (Horiz Coll 2) 417 |
| 21 | Horizontal Petri Dish Collecting Position (Horiz Coll 3) 418 |
| 22 | Horizontal Petri Dish Collecting Position (Horiz Coll 4) 419 |
| 23 | Horizontal Petri Dish Standby Position (Horiz Standby) 586 |
| 24 | Horizontal Petri Dish Release Position (Horiz Rel) 420 |
| 25 | Auto Mode (Auto) |
| 26 | Manual Mode (Manual) |
| 27 | System Parameters (Sys Params) |
| 28 | Position Setting (Pos Set) |
| 29 | Position Interface (Pos Interface) |
| 30 | Alarm Interface |
| 31 | I/O Monitor (I/O Mon) |
Position Setting 3
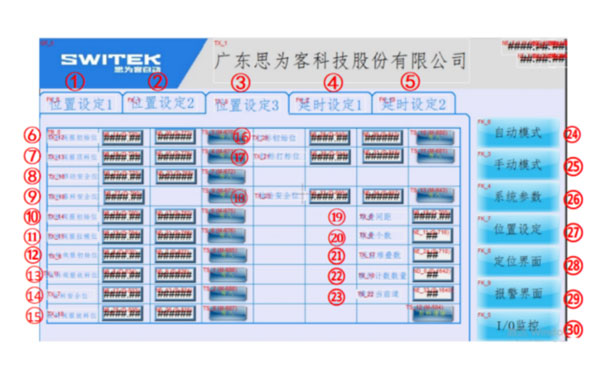
| No. | Description |
|---|---|
| 1 | Position Setting 1 (Pos Set 1) 400 |
| 2 | Position Setting 2 (Pos Set 2) 401 |
| 3 | Position Setting 3 (Pos Set 3) 402 |
| 4 | Delay Setting (Delay Set1) 403 |
| 5 | Delay Setting (Delay Set 2) 404 |
| 6 | Petri Dish Poping Servo Initial Position (Top Init Pos) 421 |
| 7 | Petri Dish Poping Servo Poping Position (Top Pos) 422 |
| 8 | Safe Moving Position (Moving Safety) 587 |
| 9 | Petri Dish Cover Dropping Safety Position (Blank Safety Pos) 730 |
| 10 | Sleeve Pulling Servo Initial Position (Pull Mold Init) 423 |
| 11 | Sleeve Pulling Starting Position (Pull Mold) 424 |
| 12 | Petri Dish Collecting Initial Position (Mat Coll Init) 479 |
| 13 | Petri Dish Pick Up Position (Pick-up Station) 576 |
| 14 | Petri Dish Collecting Safe Position (RecServo SP) 709 |
| 15 | Petri Dish Collecting Servo Parts Release Position (Mat Coll Rel) 480 |
| 16 | Mark Printing Initial Position (Maring Init Pos) 731 |
| 17 | Mark Printing Position (Adjus Maring Pos) 732 |
| 18 | Sampling Safety Position (Spot Check Safe) 746 |
| 19 | Stacking Space 481 |
| 20 | Number Stacked (Num Stacks) 482 |
| 21 | Currently Stacked Number (Stack Count) 694 |
| 22 | Horizontal Counting Number (Horiz Mat Ctr) 483 |
| 23 | Horizontal Current Counting Number (Rampant Behavior Count) 748 |
| 24 | Auto Mode (Auto) |
| 25 | Manual Mode (Manual) |
| 26 | System Parameters (Sys Params) |
| 27 | Position Settings (Pos Set) |
| 28 | Position Interface (Pos Interface) |
| 29 | Alarm Interface |
| 30 | I/O Monitor (I/O Mon) |
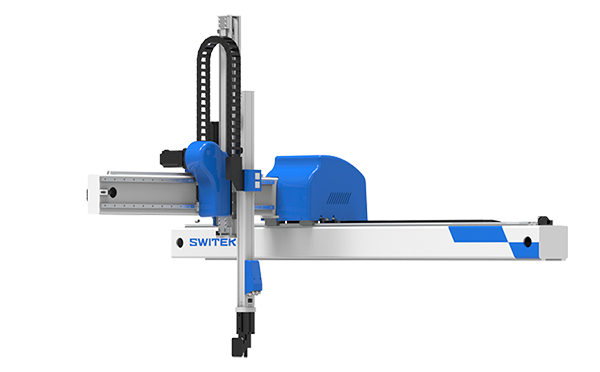
SW6715DS
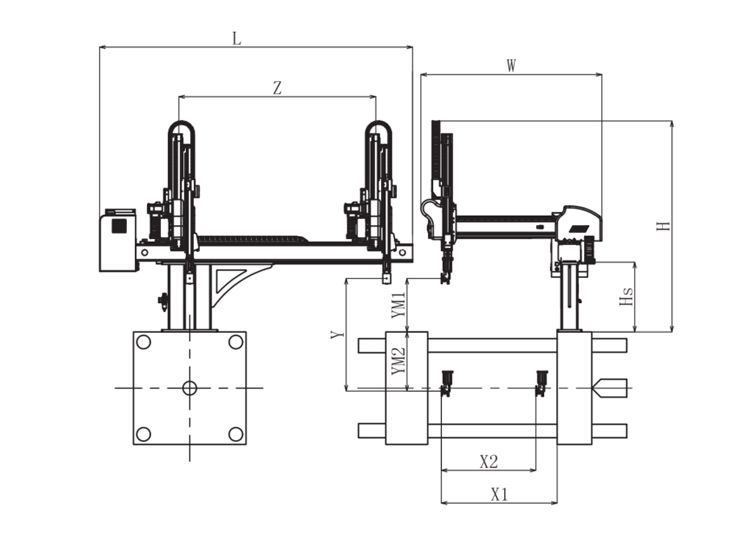
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 1400 | 1180 | 0 | 0 | 1500 | 480 | 1020 | 2500 | 3120 | 2200 | 2400 | 15kg |
|---|
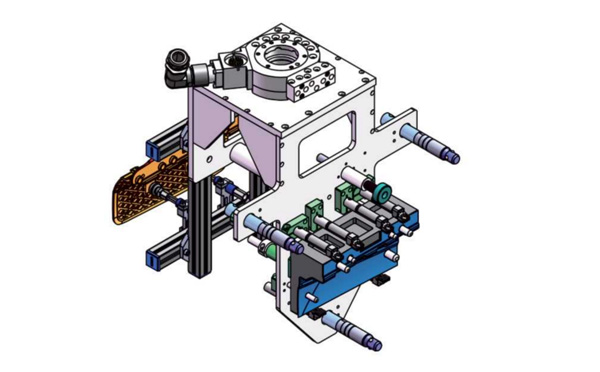
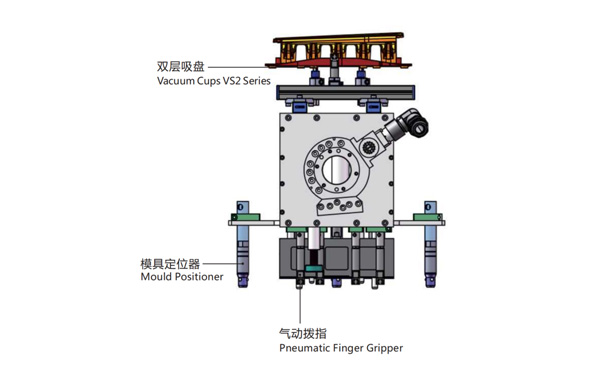
EOAT Assembly Demonstration -- One Cavity In Mold Insertion EOAT With Mold Positioner
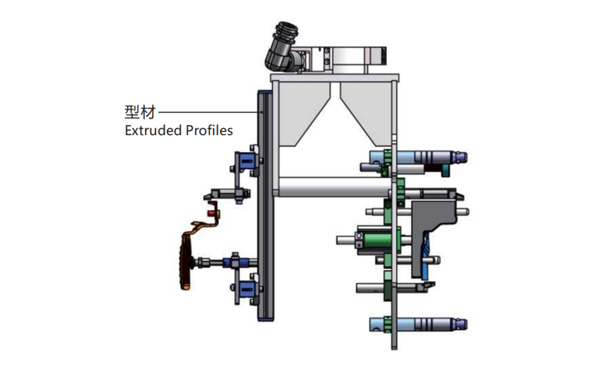
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Extruded Profiles | 4.Y00481 | PEP2525-1500 | 1 |
| Plugs for Profile | 4.Y00070 | PEP2525 | 8 |
| Mould Positioner | 8.Y00088 | GMP20A | 3 |
| Vacuum Cups VS2 Series | 1.Y05310 | VS2-SA20 | 2 |
| Rotative Suspensions | 8.Y00061 | VFR1421-G18 | 2 |
| Pneumatic Finger Gripper | 8.Y00084 | GFR14-95G | 7 |
| Extension Tube | 7.Y00733 | SMBY14-50 | 6 |
| Mounting Bracket | 7.Y00200-T | SMBE1-1440T | 3 |
| Cross Mounting Bracket for Profiles | 7.Y00194-T | SMBA-2525T | 4 |
| Vacuum Cup Fittings | 7.Y00703 | VM02-G18 | 2 |
Is there any Low Budget Solutions for PVC Pipe Fittings Runner Cutting?
PVC pipe fittings are one of the most commonly used connector in the drainage project and a cold runner designed mold is the most economic solutions for the production of the PVC pipe fittings, but the removal of the runner in result is a labour intensive work. Is there any economic way to remove the runners from the PVC pipe fittings automatically?
For the producer of PVC pipe fittings the most economic soluton to remove the runner is with an Air Nipper fixed to the picking robot immediately after the PVC pipe fittings picked out from the mould. The robot will drop the seperated pipe fittings and runner to different containers. Below configuration of SWITEK runner cutting solution for 16 cavities PVC pipe fittings for your reference:
The Air Nipper runner cutting system is an easy to start solution for the producers of PVC pipe fittings, which the Air Nipper would be controlled by the picking robot and is the best solution for the small size PVC pipe fittings (with a diameter around φ25mm). Anyway it also must be custom made according to the mold design.
For more solutions about the pipe fittings runner cuttings and other automation solutions please contact Adams from SWITEK, for a profound proposal of turn-key solutions of pipe fittings production.