sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

With the control system developed by the Austria automatic company SIGMATEK GmbH & Co KG, SWITEK high speed side entry IML robot is providing a more efficient and outstanding performance for your quality bulk production of the IML Yogurt Cups.
1.3.19 Servo Axis Running Parameters Settings (Axis)
Return to the Function page, Choose Servo axis running parameters Settings screen (This page needs level 10 of the administrator password), as the picture below 1.3.19:
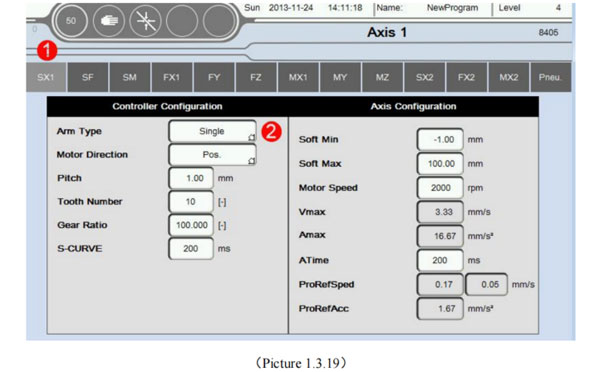
| Control parameter configuration | ||
|---|---|---|
| Arm Type | [-] | Can choose the arm is single or double, according to the actual situation |
| Motor Direction | [-] | Can choose Positive or Negative Only when useing SigmaTek drive. This setting effective; When Opposite the forward direction and the actual, can choose Positive/Negative correction; |
| Pitch | [-] | Distance between the two tooth dividing of the circles Synchronous round of reducer. |
| Tooth Number | [-] | The number of reducer of axis synchronous gear (Multiplied by the pitch is the circumference) |
| Gear Ratio | [-] | Connect the motor reducer reduction ration |
| S-CURVE | ms | Affecting the host sends pulse waveform curve. The greater the numerical, accelerate maximum speed longest, run smoother. |
| Servo parameters configuration | ||
| Soft Min | mm | Mechanical minimum position allowed, suggest to set 1.00. |
| Soft Min | mm | Mechanical maximum position allowed, according to the actual mechanical dimensions. |
| Motor Speed | RPM | Set motor rated speed, please refer to the motor nameplate rated speed setting. |
| Vmax | mm/s | Motor speed automatically calculates the maximum output value, users do not need to self-assess. |
| Amax | mm/s2 | Motor to accelerate from standstill to maximum speed, the maximum acceleration |
| ATime | ms | Motor accelerates from zero to maximum speed time required. |
| ProRefSped | mm/s | The speed of the motor back to zero |
| ProRefAcc | mm/s2 | The accelerated of the motor back to zero |
Click "SF", Show as the picture below 1.3.20 (Non Sigmatek drive setup):
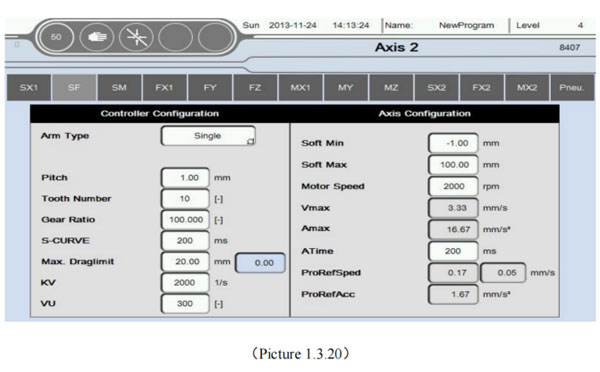
| Control parameter configuration | ||
|---|---|---|
| Arm Type | [-] | Can choose the arm is single or double, according to the actual situation |
| Pitch | mm | Distance between teh two tooth dividing of the circles Synchronous round of reducer |
| Tooth Number | [-] | The number of reducer of axis synchronous gear (Multiplied by the pitch is the circumference) |
| Gear Ratio | [-] | Connect the motor reducer reduction ratio |
| S-CURVE | ms | Affecting the host sends pulse waveform curve. The greater the numerical, accelerate to maximum speed longest, run smoother. |
| Max Draglimit | mm | Deviation between instructions position and motor actual running position |
| KV | 1/s | Proportion factor |
| VU | [-] | Integrating factor |
| Servo parameters configuration | ||
| Soft Min | mm | Mechanical minimum position allowed, suggest to set-1.00. |
| Soft Min | mm | Mechanical maximum position allowed, according to the actual mechanical dimensions. |
| Motor Speed | RPM | Set motor rated speed, please refer to the motor nameplate rated speed setting. |
| Vmax | mm/s | Motor speed automatically calculates the maximum output value, Users do not need to self-accesses. |
| Amax | mm/s2 | Motor to accelerate from standstill to maximum speed, the maximum acceleration |
| ATime | ms | Motor accelerates from zero to maximum speed the time required |
| ProRefSped | mm/s | The speed of the motor back to zero |
| ProRefAcc | mm/s2 | The accelerated of the motor back to zero |
Specific set rules can be seen in the table below:
Click "FZ", Show as the picture below 1.3.21 (Pneumatic axis setting).
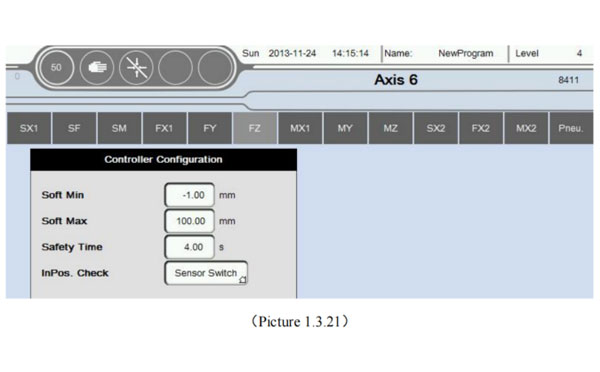
Specific set rules can be seen in the table below:
| Controller Parameter Configuration | ||
|---|---|---|
| Soft Min | mm | The minimum stroke with cylinder run (Can set indented state to the minimum position. Aso can set out of state to the minimum position). NoteⓈ |
| Soft Min | mm | The minimum stroke with cylinder run (Can set indented state to the maximum position. Also can set out of state to the maximum position). Note⑥ |
| Safety Time | s | Show as InPos. Check |
| InPos.Check | [-] | Which method you choose determines detection in place, Sensor Switch/Safety Time
|
Click "Pneu.axis", Show as the picture below 1.3.22
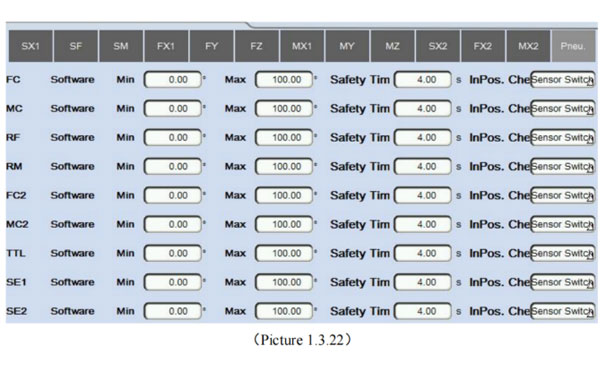
Specific set rules can be seen in the table below:
"FC" "MC" are Pneu, Axis. The specific set of rules, as list in the following table.
| Controller configuration | ||
|---|---|---|
| Soft Min | ° | As the above-mentioned Note Ⓢ |
| Soft Max | ° | As the above-mentioned Note ⑥ |
| Safety Time | s | As the below inPos.Check |
| inPos.Check | As the above-mentioned Note ⑦ | |
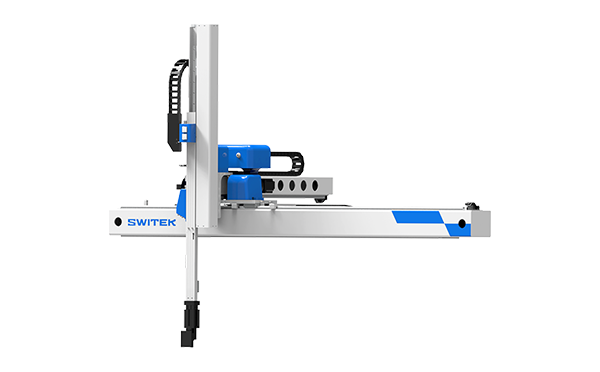
SW7112DS
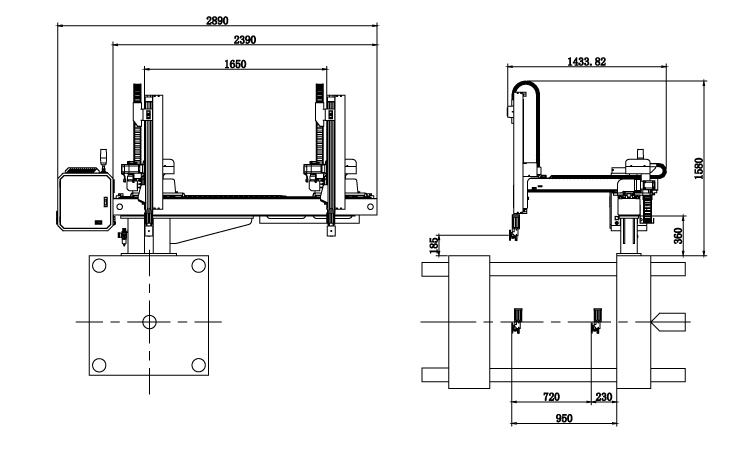
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 950 | 720 | 0 | 0 | 1200 | 425 | 775 | 1650 | 2710 | 1434 | 1780 | 5kg |
|---|
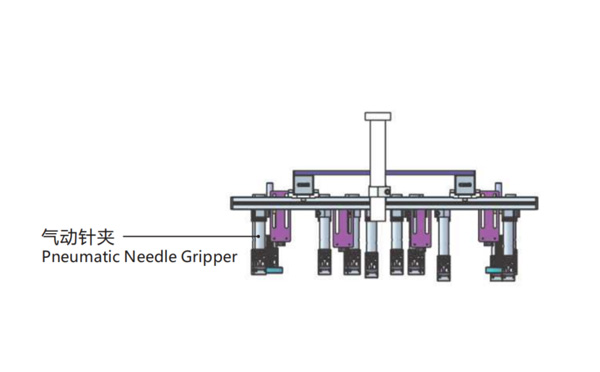
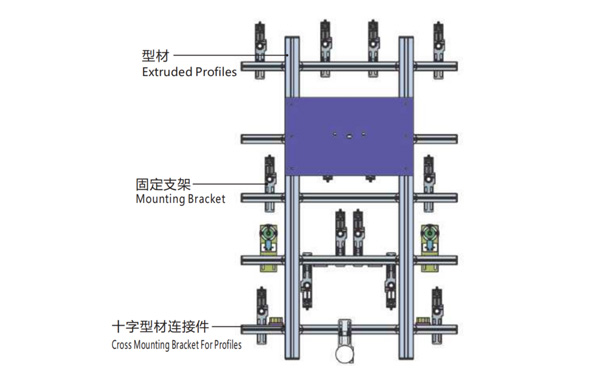
EOAT Assembly Demonstration -- Two Cavities Non-woven Fabric In Mold Insertion
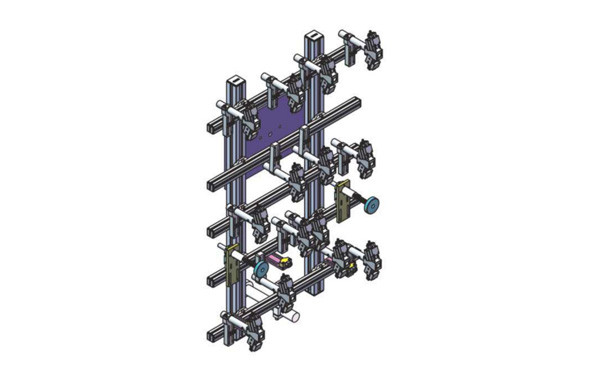
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Extruded Profiles | 4.Y00052 | PEP4040-1000 | 2 |
| Plugs for Profile | 4.Y00072 | PEP4040 | 4 |
| Extruded Profiles | 4.Y000481 | PEP2525-1500 | 2 |
| Extruded Profiles | 4.Y00481 | PEP2525-1000 | 1 |
| Plugs for Profile | 4.Y00070 | PEP2525 | 10 |
| Cross Mounting Bracket for Profiles | 7.Y00356-T | SMBA-2540T | 10 |
| Pneumatic Needle Gripper | 8.Y00025 | GN2010 | 14 |
| Mounting Bracket | 7.Y00308-T | SMBE2-2060T | 14 |
| Mounting Bracket | 7.Y00309-T | SMBE2-3060T | 1 |
For Small and Medium Sized IML Container Producer, Is it Possible to Produce More the One Products with the Same IML Robot?
For manay small and medium sized producer of IML containers it many not be easy to make a decision if to accept the order or not because of the small quantity at the beginning but a huge potential in the future. As the IML robot is a custom made system according to the mold design and the injection molding machine for this mold. But is there any possibility to have one IML robot for a couple of molds? The answer is yes.
The SW8 series of side entry IML robot is one of which an ideal choice for the small and medium sized producer of IML containers. With exchangeable magazine and stacking unit, the IML robot enable the IML containers producers to produce the small and medium sized IML containers and IML lids by the injection molding machine and the IML robot with simply to have the magazine and EOAT replaced for the new mold. But with this IML robot, how will the IML containers produce to achieve the maximized productivity?
To maximized the productivity of the IML system, the key would be to have the injection molding machines and the IML robots well organized according to the products. To make the change the magazine and EOATs faster, we can have the containers with wraping labeling produced in one IML system and have the 3/5 face labeling containers and the lids produced by another IML system. It's not recommended to have the containers with wraping labeling to be produced by the same IML system with an IML lids, which will need to change both the Magazine and the stacking unit and the time to start the system up would be much longer.
For more advisory of an IML project planning please feel free to contact Adams from SWITEK Automation, your personal consultant of IML system integration.