sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

Keywords:IML Robot; IML Robot Operating; In Mold Labeling Robotics
While an IML robot is in production of the IML containers, the robotic arm will pick the parts out and have them placed on the conveyor. In this chapter we'll introduce how to design the stacking and layout format of the parts on the conveyor in your program.
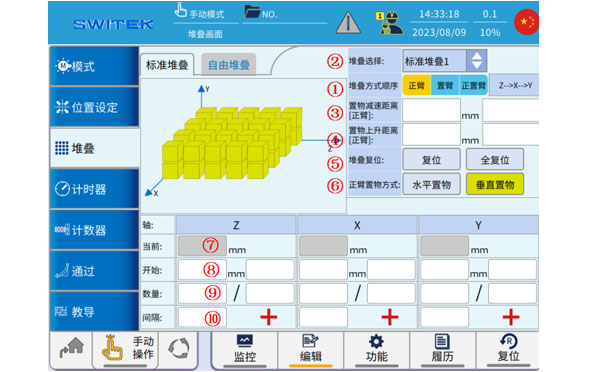
Standard stacking
| No. | Name | Function |
|---|---|---|
| (1) | Stacking mode | Select the axis order setting that will be prioritized when the stack runs. |
| (2) | Select | 8 Stacks, click to select the stack number that is currently set. |
| (3) | Decline deceleration | Click to set the distance and speed of the stack run before decelerating into place. |
| (4) | Ascending deceleration | Click to set the stack to run and decelerate after the start of the ascent and the speed. |
| (5) | Stack reset | Reset: The current stack-related data is reset. Full Reset: All stack-related data is reset. |
| (6) | Placement mode | Horizontal placement: that is, the product is placed in the side posture of the fixture; Vertical storage: that is, the fixture is back to the normal state to put the product. |
| (7) | The current value of the axis | The current position of each axis is displayed. |
| (8) | Start position | The start point/speed at which each axis is stacked. |
| (9) | Interval number | Sets the current number of stacks or the total number of stacks in each axis. |
| (10) | Interval value | Set the interval value for each axis. |
Standard stacking is generally used for placing products at equal spacing, and by setting up stacking groups on this page, when placing products, they will be placed according to the setting. If you take out multiple products at a time (using multiple sets of suction holders), you can select "products are packed separately" in the mode, and then set up multiple stacks, and the products on each suction jig will be placed in the corresponding stacking matrix during operation.
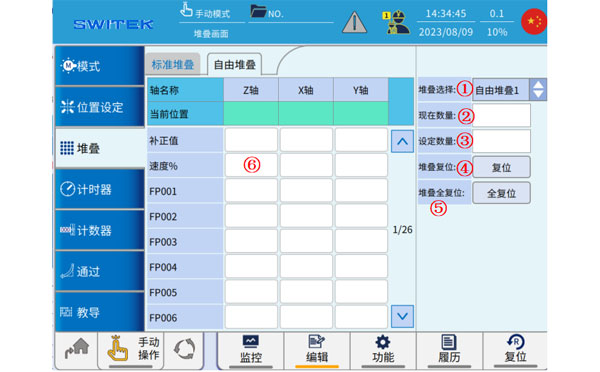
Free Stack
| No. | Name | Function |
|---|---|---|
| (1) | Stacking selection | 8 Free stacks, click to select the current set free stack number. |
| (2) | Current quantity | The number of stack points that are currently running. |
| (3) | Setting number | The total number of points that are freely stacked. |
| (4) | Stack reset | Click to reset the current free stack. |
| (5) | Stack full reset | Click to reset all free stacks. |
| (6) | Speed % | Set the running speed of each axis. |
Free stacking is generally used for understand and irregular point product placement, first select (1) free stacking number, then set (3) stacking point number, and then set the position of each point in turn. Free stacking is generally used when using the teaching program, and after setting it up, you need to edit the relevant call logic in the teaching.

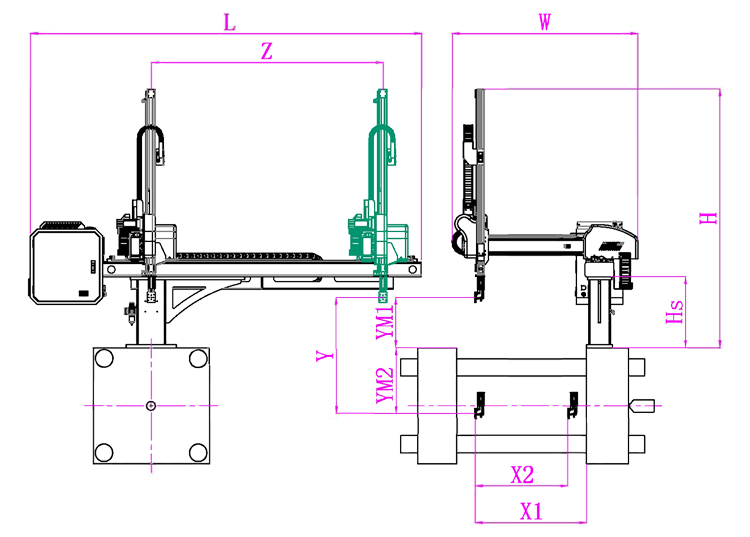
SW6310S-20
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 980 | 820 | 0 | 0 | 1000 | 235 | 765 | 1580 | 2640 | 1500 | 1930 | 3kg |
|---|
EOAT Assembly Demonstration -- Two Cavities Parts Picking EOAT with Runner Cutting by Air Nipper
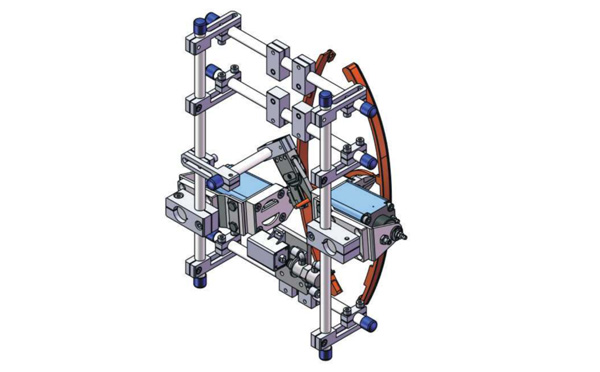
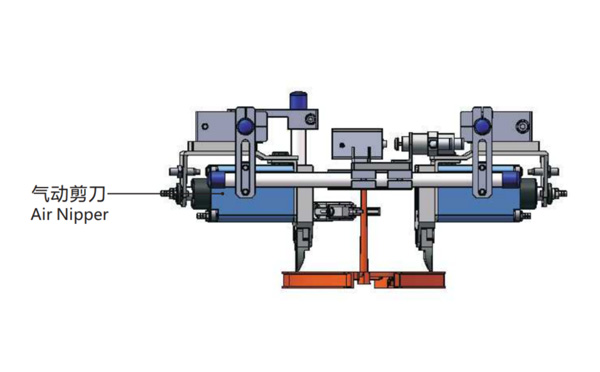
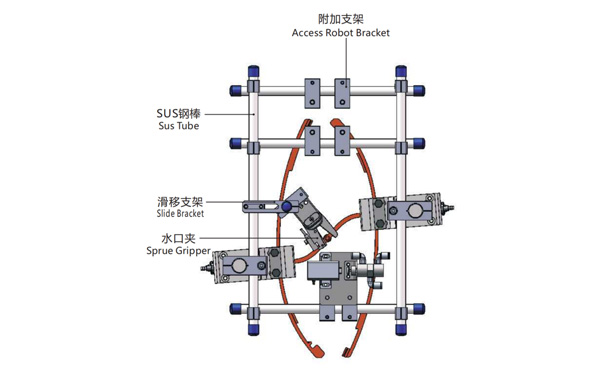
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Sus Tube | 4.Y00021 | PST12-1500 | 2 |
| Air Nipper | 1.Y00004 | GT-NY25 | 2 |
| Straight Blades for Plastic | 1.Y00037 | NY25AJ | 2 |
| Fixing Block | 7.Y00633 | SCE2-25 | 2 |
| Tube Plugs | 1.Y03638 | PST12-1500 | 11 |
| Cross Connector | 7.Y00027 | SMBT-2012 | 2 |
| Access Robot Bracket | 7.Y00002 | SMBH1-12M6 | 6 |
| L-Type Thread Hose Fitting | 1.Y02809 | APL6-M5 | 3 |
| Slide Bracket | 7.Y00004 | SCF4-1240W16 | 7 |
| Slide Bracket | 7.Y00001 | SMBS-12T16 | 7 |
| Sprue Gripper | 8.Y00091 | GR12-12-CN | 1 |
| Cross Connector | 7.Y00020 | SMBT-1212 | 1 |
What Would be the Best Picking Robot for LK FA1200 in a Dustbin Production Project?
FA1200 is a Two-palten energy-saving servo injection molding machine produced by LK machinery for the production of automotive parts, home appliances, sanitation buckets, pallets, pipe fittings etc. As a Two-platen injection molding machine, it's an ideal choice for the production of deep cavity container like dustbin. For a project of dustbin production, which robot would be the best for this injection molding machine?
As a Two-platen injection molding machine with a clamping force of 12000kN, LK FORZA FA1200 has an opening stroke of 2100mm with a max mold thickness up to 1300mm, it'll be suitable to produce a dustbin with a maximum height up to 650mm without IML. To pick the dustbin only the 3 axis servo injection robot SW7518DS by SWITEK Automation would be the best one.
SW7518DS is a medium sized 3 axis servo injection robot designed for the injection molding machine with clamping force from 500T ~ 1500T with a payload up to 15kg. As a kick-back designed robot, it'll provide 30% more space for EOAT moving and a perfect mate to a deep cavity product like dustbin picking.
Starting from 2006, SWITEK is providing the OEM/ODM service of robotic arms for injection automation from Sprue picker to heavy duty robot with payload up to 75kg to match injection molding machine up to 4000T with turn-key injection automation solutions. For more information about SWITEK robotic arms and injection automation solution please contact Adams, your personal consultant of injecdtion automation solution integration.