
sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

Keywords:IML Robot; IML Robot Operating; In Mold Labeling Robotics
The "Production management" page is where for the factory owner to whatch up the production status of the IML system to optimize the production and improve the quality of the IML containers produced. Here in this chapter we'll introduce the setting of the "Production management" of the IML robot.
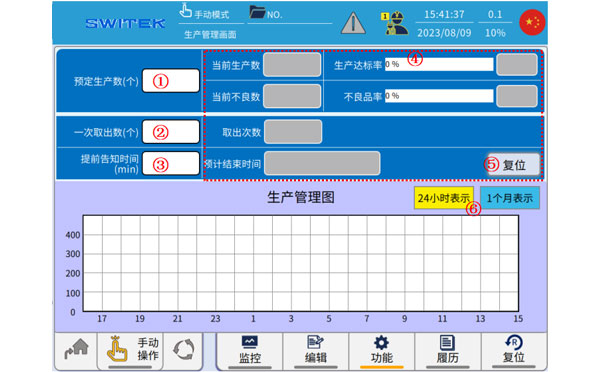
| No. | Name | Function |
|---|---|---|
| (1) | Scheduled production number | Click to set the total number of items to be produced. When this is achieved, it will automatically stop and prompt. |
| (2) | The number of take-outs at once | Click to set the number of products to be removed per cycle. |
| (3) | The moment of start of producdtion | Click the start time for production. |
| (4) | Current production numbers | The number of units currently produced is displayed. |
| Production achievement rate | The ratio of the number of completed production units to the nubmer of scheduled producdtions, that is, the production progress. | |
| The current number of defects | The number of defective products accumulated by the current production. | |
| Defective product rate | The ratio of the number of defective products to the total number of products produced. | |
| Number of take-outs | The number of times it was taken out cumulatively. | |
| Estimated end time | The expected time for the system to complete the scheduled number of productions. | |
| (5) | Reset | Click to reset the display number at (4) to zero |
| (6) | 24h/1 Month production curve | Click to switch the time field of the production management chart. |

SW6712D-20
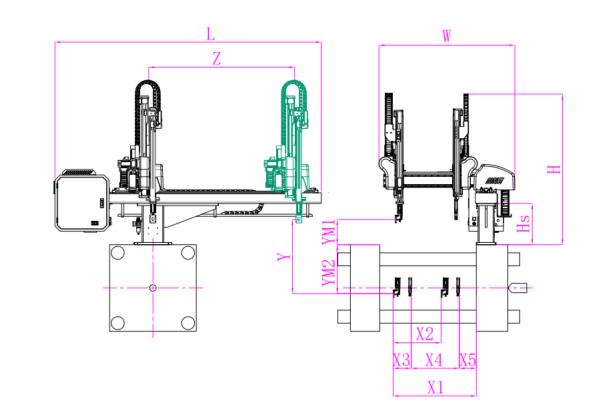
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 1025 | 605 | 250 | 590 | 1200 | 475 | 725 | 2000 | 3020 | 1610 | 2050 | 8kg |
|---|
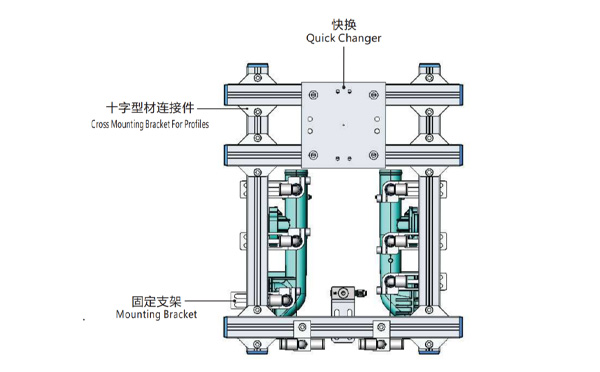
EOAT Assembly Demonstration -- Two Cavities Parts Picking EOAT with Runner Gripping
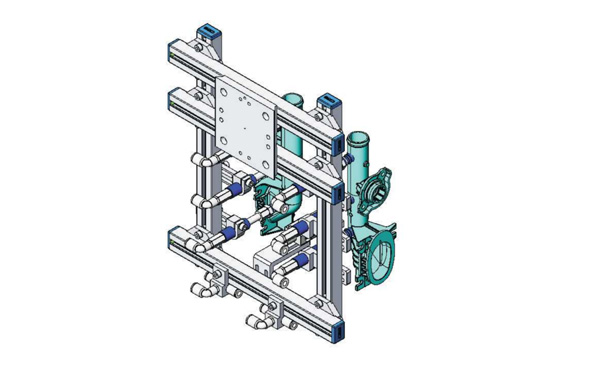
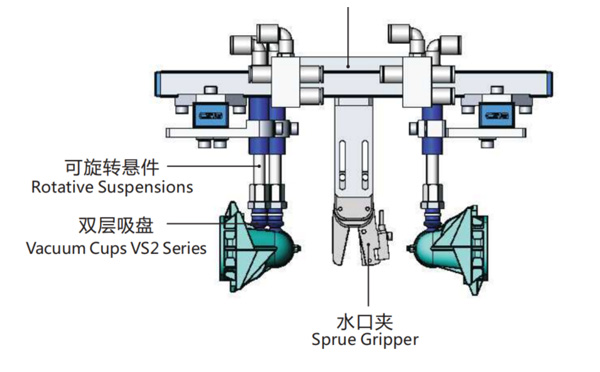
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Quick Changer | 7.Y00175 | QCS-G100 | 1 |
| Sprue Gripper | 8.Y00050 | GR12-12CP | 1 |
| Plugs for Profile | 4.Y00069 | PEP2518 | 10 |
| Cross Mounting Bracket for Profiles | 7.Y00194 | SMBA-2525T | 6 |
| Extruded Profile | 4.Y00455 | PEP2518-1000 | 2 |
| Vacuum Cups VS2 Series | 1.Y03085 | VS2-SA11 | 6 |
| Vacuum Cup Fitting | 7.Y00703 | VM-02-G18 | 6 |
| Rotative Suspensions | 8.Y00061 | VFR1421-G18 | 6 |
| Mounting Bracket | 7.Y00200 | SMBE1-1440T | 6 |
| Connector | 1.Y02510 | APF-M5 | 2 |
| Side Manifold Block | 7.Y00157 | SMB-06M5 | 2 |
| L-Type Threaded HOse Fitting | 1.Y02722 | APL6-01 | 8 |
| Straight Threaded Hose Fitting | 1.Y02725 | APC6-01 | 6 |
For vision control system for IML containers, what's the advantages and disadvantages of the open type of vision control system?
Vision control is now a very important in IML system especially the IML solutions for dairy products packages like yogurt cups, butter cups etc. For most European IML solutions providers like BRINK that they'll choose an open type of Vision control system which will check if the containers are well labeled or not immediately after the containers picked out from the mold and have them re-stacked after the vision control. This kind of solution will help to increase the efficiency of the IML System and pick out the defect parts quickly.
But, for some minor defect like dirt it would be impossible to be checked out because the precision of the cameras would be influenced by the changing light of the environment. To solve this problem the updated solution would be to have the IML containers checked in a closed light box which will creat a stable environment to the camera to minimize the misjudgement of the good and non good parts. -- SWITEK Yogurt Cups Vision Control Solution


