sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

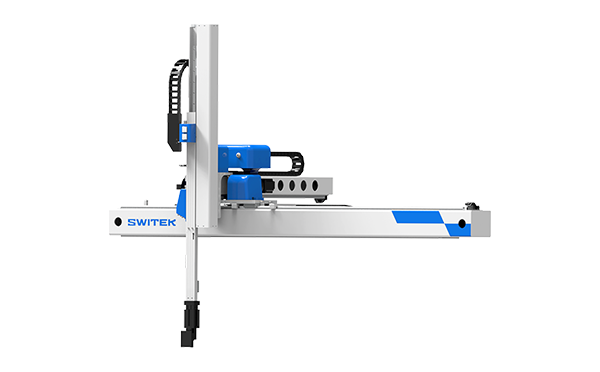
With the control system developed by the Austria automatic company SIGMATEK GmbH & Co KG, SWITEK high speed side entry IML robot is providing a more efficient and outstanding performance for your quality bulk production of the IML Yogurt Cups.
3.1 Delay and speed
Click Time button, entry into the page of Delay and speed. As shown in the below picture 1.5.1:

: The continuous time for the AirBlow. The AirBlow will be cut off automatically when the continuous time reaches the setting time;
: The continuous time for the Conveyor belt outputs. The Conveyor belt will be cut off automatically when the continuous time reaches the setting time;
: Ejector front enable delay. The module will not output instructions to machine until it reaches the setting delay time when program output the ejector enable instruction;
: As the above description;
: The machine will not receive the order of input until it reaches the setting time when machine outputs the order of Modulo Open Confirm Delay;
: The interval time between modulo receives two signals of Module Open. When the actual interval time is below the setting time, the modulo will give an alarm signal to prevent us to make a true estimate from interferential signals.
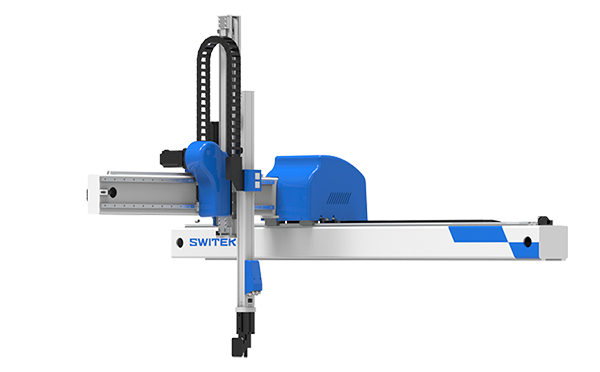
SW6308DS-20
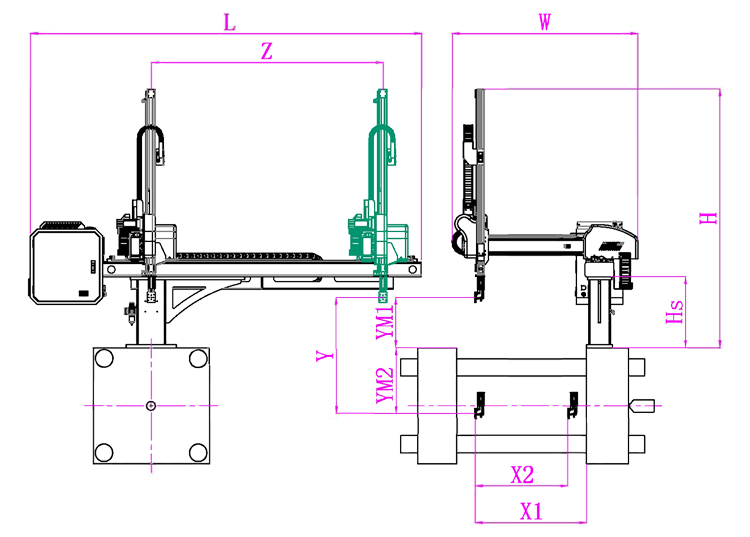
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 740 | 800 | 0 | 0 | 800 | 235 | 565 | 1350 | 2320 | 1500 | 1460 | 3kg |
|---|
EOAT Assembly Demonstration -- Two Cavities Parts Picking EOAT with Runner Gripping
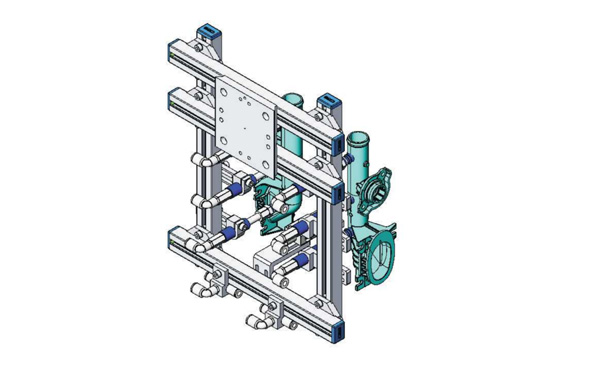
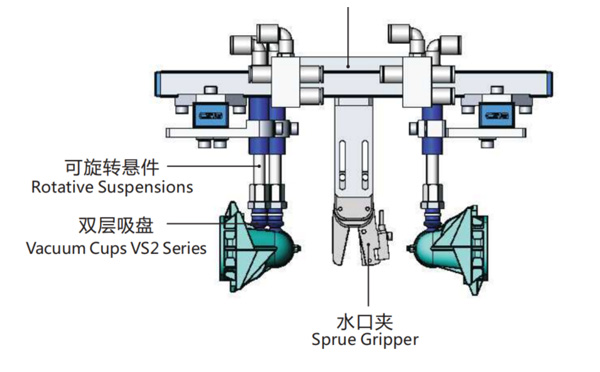
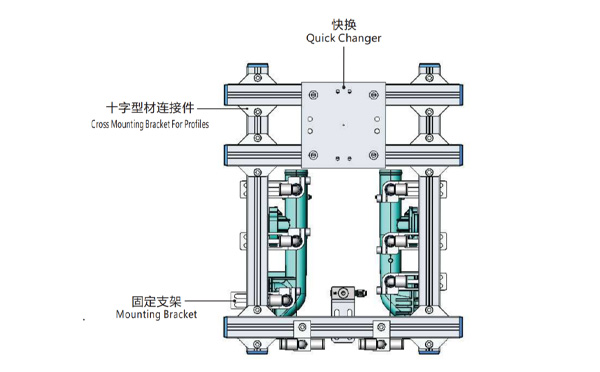
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Quick Changer | 7.Y00175 | QCS-G100 | 1 |
| Sprue Gripper | 8.Y00050 | GR12-12CP | 1 |
| Plugs for Profile | 4.Y00069 | PEP2518 | 10 |
| Cross Mounting Bracket for Profiles | 7.Y00194 | SMBA-2525T | 6 |
| Extruded Profile | 4.Y00455 | PEP2518-1000 | 2 |
| Vacuum Cups VS2 Series | 1.Y03085 | VS2-SA11 | 6 |
| Vacuum Cup Fitting | 7.Y00703 | VM-02-G18 | 6 |
| Rotative Suspensions | 8.Y00061 | VFR1421-G18 | 6 |
| Mounting Bracket | 7.Y00200 | SMBE1-1440T | 6 |
| Connector | 1.Y02510 | APF-M5 | 2 |
| Side Manifold Block | 7.Y00157 | SMB-06M5 | 2 |
| L-Type Threaded HOse Fitting | 1.Y02722 | APL6-01 | 8 |
| Straight Threaded Hose Fitting | 1.Y02725 | APC6-01 | 6 |
What is a Picking Robot?
A picking robot in an injection project is a robotic arm which will pick the parts from the mould and have it placed on the conveyor or other automation system to have another processing. The projector will choose a picking robot according to the size of the injection molding machine, the injection cycle time, the weight of the parts etc to choose a picking robot.
Take the SWITEK hgih speed 3 axis servo robot SW7112DS as an example, with a pay load of 2kg and a dry cycle time of 3.3s only designed for injection molding machine ranging from 150Ton ~ 500Tone, it could be regarded as one of the best picking robot for the thin-wall containers production business with a picking capacity up to 8 cavities of 700ml cups, but if for the picking of a bumper it would not be suitable. Anyway, to choose a picking robot for your injection project, the key point would be: