sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

Keywords:PETRI DISH PACKING SYSTEM, PETRI DISH INJECTION MOLDING SOLUTIONS
The cylinders in the SWITEK Side Entry Petri Dish Packing System plays a key role in the parts picking, assembly, stacked petri dishes poping, sleeve opening, sealed bags delivery etc. Here in this chapter we're introducing how to set the cylinders in the petri dish system to make them working properly.
Cylinder Manual Setting 1

| No. | Description |
|---|---|
| 1 | Manual Cylinder (Man Cyl) 1 |
| 2 | Manual Cylinder (Man Cyl) 2 |
| 3 | Manual Servo (Servo Man) 1 |
| 4 | Manual Servo (Servo Man) 2 |
| 5 | Auto Mode (Auto) |
| 6 | Manual Mode (Manual) |
| 7 | System Parameters (Sys Params) |
| 8 | Position Setting (Pos Set) |
| 9 | Position Interface (Pos Interface) |
| 10 | Alarm Interface |
| 11 | I/O Monitor (I/O Mon) |
| 12 | Main Arm Clampling (M Arm Clamp) (OFF) |
| 13 | Receive Cylinder (Receiv Cyl) 1 |
| 14 | Receive Cylinder (Receiv Cyl) 2 |
| 15 | Combine Cylinder (Comb Cyl) 1 |
| 16 | Combine Cylinder (Comb Cyl) 2 |
| 17 | Ejector Cylinder (Ejector Cyl) |
| 18 | Sampling (Random) Cylinder |
| 19 | Block Cylinder (Block Cyl) 1 |
| 20 | Block Cylinder (Block Cyl) 2 |
| 21 | Block Cylinder (Block Cyl) 3 |
| 22 | Block Cylinder (Block Cyl) 4 |
| 23 | Clamping Cylinder (Pneu Cyl Clanp) |
| 24 | Back Block Cylinder (Back Cyl) 1 (OFF) |
| 25 | Back Block Cylinder (Back Cyl) 2 (OFF) |
| 26 | Back Block Cylinder (Back Cyl) 3 (OFF) |
| 27 | Back Block Cylinder (Back Cyl) 4 (OFF) |
| 28 | Main Arm Static Eliminate (Arm ESD) (OFF) |
| 29 | Stack Static Eliminate (Stack ESD) (OFF) |
Cylinder Manual Setting 2

| No. | Description |
|---|---|
| 1 | Manual Cylinder 1 (Man Cyl1) |
| 2 | Manual Cylinder 2 (Man Cyl2) |
| 3 | Manual Cylinder 3 (Man Cyl3) |
| 4 | Euromap Page (EU Page) |
| 5 | Manual Servo (Servo Man 1) |
| 6 | Auto Mode (Auto) |
| 7 | Manual Mode (Manual) |
| 8 | System Parameters (Sys Params) |
| 9 | Position Setting (Pos Set) |
| 10 | Position Interface (Pos Interface) |
| 11 | Alarm Interface |
| 12 | I/O Monitor (I/O Mon) |
| 13 | Left Sleeve Clamping Cylinder (Left Clamp) (OFF) 126 |
| 14 | Upper Left Sleeve Clamping Cylinder (UL_Clamping_Cyl) 625 |
| 15 | Upper Left Sleeve Pull Cylinder (UL_Ejector_Cyl) 626 |
| 16 | Lower Left Sleeve Clamping Cylinder (L Left Clamp) (OFF) 128 |
| 17 | Lower Left Sleeve Pull Cylinder (L Left Push Mold) 129 (OFF) |
| 18 | Top Sleeve Lifting Cylinder (Top Mold Lift) 132 |
| 19 | Top Sleeve Opening Cylinder (Top Mold Open) (OFF) 133 |
| 20 | Upper Left Sleeve Sealing Cylinder (Upper L Weld) (OFF) 134 |
| 21 | Upper Right Sleave Sealing Cylinder (Upper R Weld) (OFF) 135 |
| 22 | Lower Left Sleeve Sealing Cylinder (Lower L Weld) (OFF) 136 |
| 23 | Lower Right Sleeve Sealing Cylinder (Lower R Weld) (OFF) 137 |
| 24 | Sleeve Clamping Cylinder (Mat Coll Clamp) (OFF) 138 |
| 25 | Sleeve Cutting Cylinder (Cutting Mold) (OFF) 139 |
| 26 | Sleeve Suck Vacuum (Suck Mold Vac) (OFF) 140 |
Cylinder Manual Setting 3

| No. | Description |
|---|---|
| 1 | Manual Cylinder (Man Cyl 1) |
| 2 | Manual Cylinder (Man Cyl 2) |
| 3 | Manual Cylinder (Man Cyl 3) |
| 4 | Manual Servo (Servo Man 1) |
| 5 | Manual Servo (Servo Man 2) |
| 6 | Auto Mode (Auto) |
| 7 | Manual Mode |
| 8 | System Parameters (Sys Paramas) |
| 9 | Position Setting (Pos Set) |
| 10 | Position Interface (Pos Interface) |
| 11 | Alarm Interface |
| 12 | I/O Monitor (I/O Mon) |
| 13 | Vacuum Cylinder (Vac Cyl) (OFF) 647 |
| 14 | Material Suck (OFF) 648 |
| 15 | Sleeve Clamping Up/Down Cylinder (Borrow V Cyl) (OFF) 649 |
| 16 | Sleeve Clamping Horizontal Cylinder (Borrow H Cyl) (OFF) 650 |
| 17 | Lower Left Sleeve Clamping Cylinder (LL Clamp Cyl) 703 |
| 18 | Upper Right Sleeve Push Cylinder (UR Ejector Cyl) (OFF) 652 |
| 19 | Sleeve Press Cylinder (Press Cyl) (OFF) 653 |
| 20 | Parts Delivery Servo Motor (FPC Motor) (OFF) 654 |
| 21 | Sleeve Feeding Motor (Mold Feed Mtr) 655 (OFF) |
| 22 | Printer Switch (Code Switch) 656 (OFF) |
| 23 | Heat Switch 657 (OFF) |
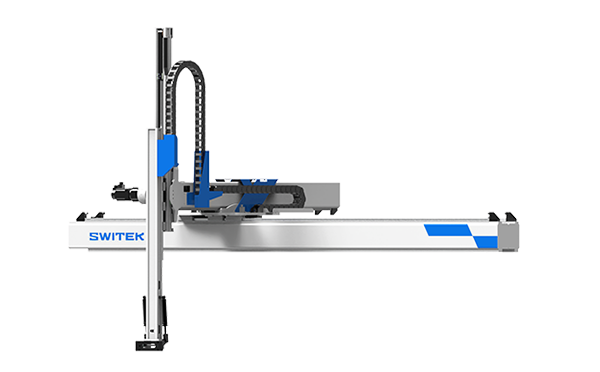
SW7312DS
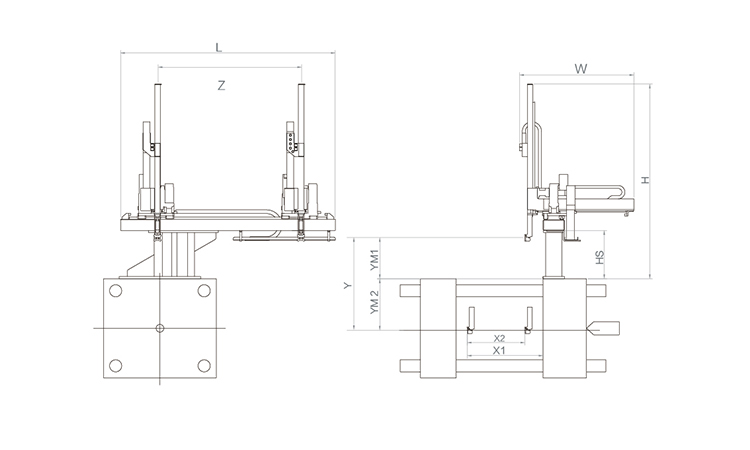
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 1020 | 730 | 0 | 0 | 1200 | 450 | 750 | 1700 | 2600 | 1660 | 2110 | 5kg |
|---|
EOAT Assembly Demonstration -- Two Cavities Parts Picking EOAT with Runner Gripping
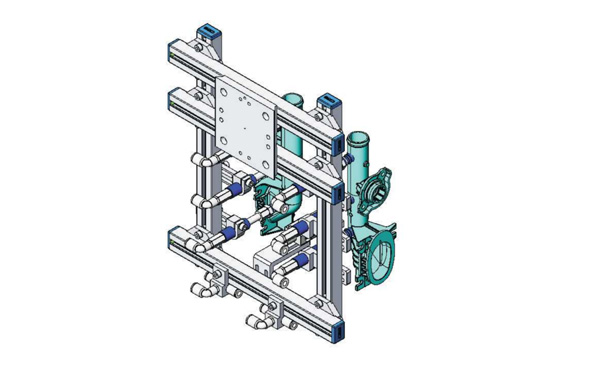
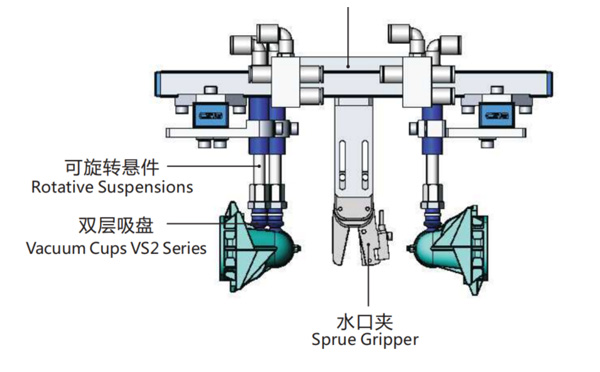
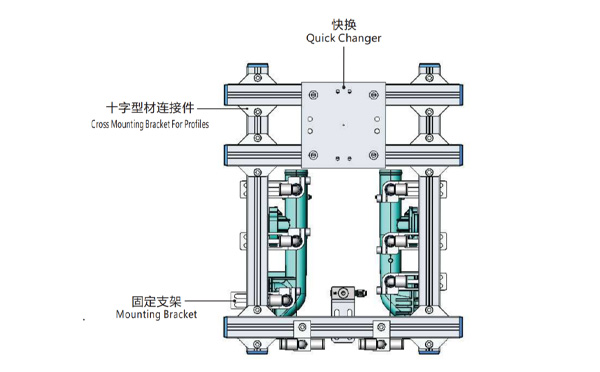
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Quick Changer | 7.Y00175 | QCS-G100 | 1 |
| Sprue Gripper | 8.Y00050 | GR12-12CP | 1 |
| Plugs for Profile | 4.Y00069 | PEP2518 | 10 |
| Cross Mounting Bracket for Profiles | 7.Y00194 | SMBA-2525T | 6 |
| Extruded Profile | 4.Y00455 | PEP2518-1000 | 2 |
| Vacuum Cups VS2 Series | 1.Y03085 | VS2-SA11 | 6 |
| Vacuum Cup Fitting | 7.Y00703 | VM-02-G18 | 6 |
| Rotative Suspensions | 8.Y00061 | VFR1421-G18 | 6 |
| Mounting Bracket | 7.Y00200 | SMBE1-1440T | 6 |
| Connector | 1.Y02510 | APF-M5 | 2 |
| Side Manifold Block | 7.Y00157 | SMB-06M5 | 2 |
| L-Type Threaded HOse Fitting | 1.Y02722 | APL6-01 | 8 |
| Straight Threaded Hose Fitting | 1.Y02725 | APC6-01 | 6 |
How is SWITEK 4 Cavities Pipe Strap Base Nuts In Mold Insertion System Work?
SWITEK 4 cavities pipe strap base nuts in mold insertion system is an automation solutions designed for the production of the PVC pipe strap base which is used for the on ceiling fixing of the pipes, below is the configuration of the pipe strap base production system:
The function of the SWITEK 4 cavities PVC pipe strap base injection automation solution include the nuts sorting, in mold insertion, parts picking and runner cutting. It enables the pipe strap base producer to produce it automatically.
For more solutions of PVC/PPR pipe fittings injection automation solutions please contact Adams from SWITEK to get a professional solutions of turn-key pipe PVC/PPR pipe fittings injection automation solutions.