sales06@switek.biz

+86 186 5927 5869

Shopping

Subscrib to Us
sales06@switek.biz
+86 186 5927 5869
Shopping
Subscrib to Us

With the control system developed by the Austria automatic company SIGMATEK GmbH & Co KG, SWITEK high speed side entry IML robot is providing a more efficient and outstanding performance for your quality bulk production of the IML Yogurt Cups.
1.3.12 Base Setting
Click Base Setting button into Base Setting screen, as the picture below 1.3.12;
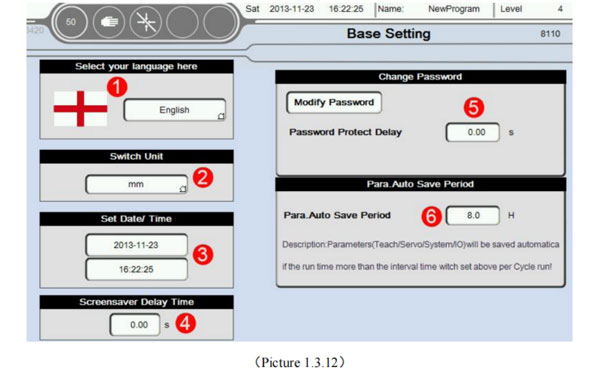
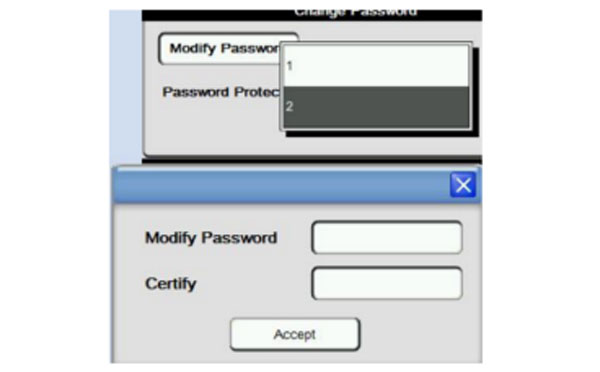
First choose the password that need to modify. Selected and input the password of modified to the password change. Second input confirm password again in the confirmation field. Finally click ok button to compete the password change.
1.3.13 Product Setup
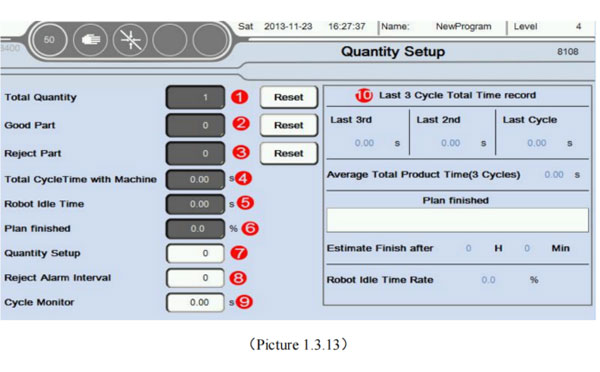
Click Product Setup button into quantity screen, as the picture below 1.3.13:

SW6310D-20
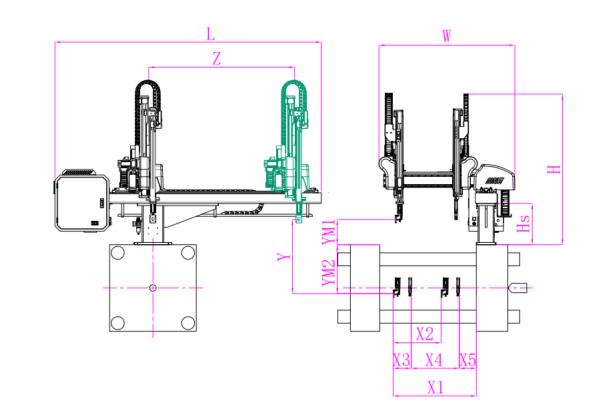
Unit: mm
| X1 | X2 | X3 | X4 | Y | YM1 | YM2 | Z | L | W | H | Payload | 740 | 640 | 140 | 415 | 1000 | 235 | 765 | 1650 | 2640 | 1500 | 1580 | 3kg |
|---|
EOAT Assembly Demonstration -- One Cavity In Mold Insertion EOAT With Mold Positioner
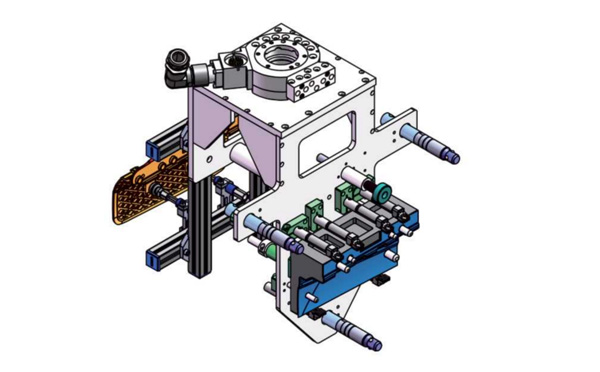
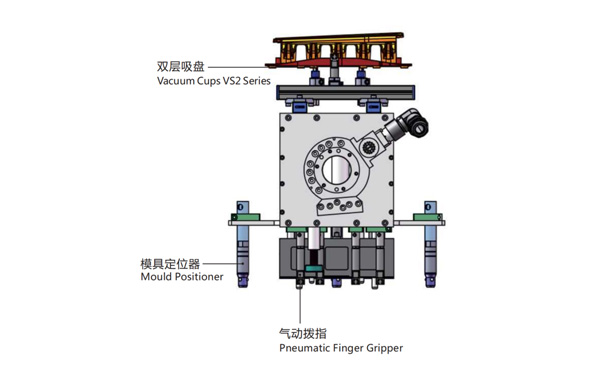
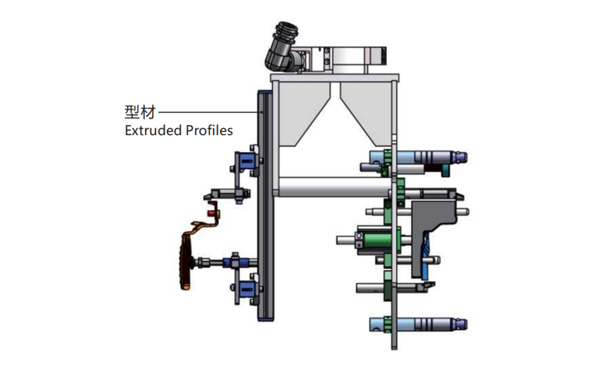
Product Descriptions
Bom List
| Product Name | PN # | Model | Quantity |
|---|---|---|---|
| Extruded Profiles | 4.Y00481 | PEP2525-1500 | 1 |
| Plugs for Profile | 4.Y00070 | PEP2525 | 8 |
| Mould Positioner | 8.Y00088 | GMP20A | 3 |
| Vacuum Cups VS2 Series | 1.Y05310 | VS2-SA20 | 2 |
| Rotative Suspensions | 8.Y00061 | VFR1421-G18 | 2 |
| Pneumatic Finger Gripper | 8.Y00084 | GFR14-95G | 7 |
| Extension Tube | 7.Y00733 | SMBY14-50 | 6 |
| Mounting Bracket | 7.Y00200-T | SMBE1-1440T | 3 |
| Cross Mounting Bracket for Profiles | 7.Y00194-T | SMBA-2525T | 4 |
| Vacuum Cup Fittings | 7.Y00703 | VM02-G18 | 2 |
For A 20L IML Bucket Project, Which of the JUPITER Series Injection Molding Machine is the Best Choice?
For A 20L IML Bucket Project, Which of the JUPITER Series Injection Molding Machine is the Best Choice?
20L IML bucket is now a very popular solution as the package of the branded paints with it's easy production and dynamic image design. To choose an injection molding machine among the JUPITER series machinery, the most important parameter to consider is the opening stroke of the injection molding machine of which to ensure that the robotic arm will have sufficient moving space in mold to put in the label and pick the parts.
To start a project of 20L IML paint pail, first of all we must have the 3D dimensional measurement of the bucket especially the height of it. For most of the 20L IML pail the height would be around 350mm, to ensure that the IML robot will have sufficient space in the mold to put the lalbel and pick the IML buckets out, the minimum opening stroke of the injection molding machine would be around 850mm, so the best of JUPITER two platen injection molding for your 20L paint pails would be JU7500 which the mold opening stroke is 1400/900mm.
For more information of an IML projection planning please feel free to contact Adams from SWITEK to get a ready to work turn-key solutions of IML container production.